The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) is a soft robotic hand rehabilitation device designed to assist finger movement, hand opening and closing, and selected hand-function exercises. It uses a powered glove mechanism to support controlled finger flexion and extension, helping patients practise repetitive hand movements as part of a structured physiotherapy or neurorehabilitation program.
The C11 is designed for professional rehabilitation environments and guided home-rehabilitation use where appropriate. Its wearable glove design supports the hand while the powered system assists selected movements. Depending on the supplied configuration, the C11 can provide training options such as passive movement, mirror training, active training, pinch exercises, finger-splitting practice, stretching and task-oriented activities.
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) can be considered for physiotherapy clinics, hospitals, occupational therapy departments, stroke rehabilitation centres and other facilities that provide hand and upper-limb rehabilitation.
PHYSIOMODALITIES™ offers professional physiotherapy and rehabilitation equipment designed to support modern clinical treatment and functional recovery programs.
What Is the Syrebo Soft Robotic Rehabilitation Glove (C11 Model)?
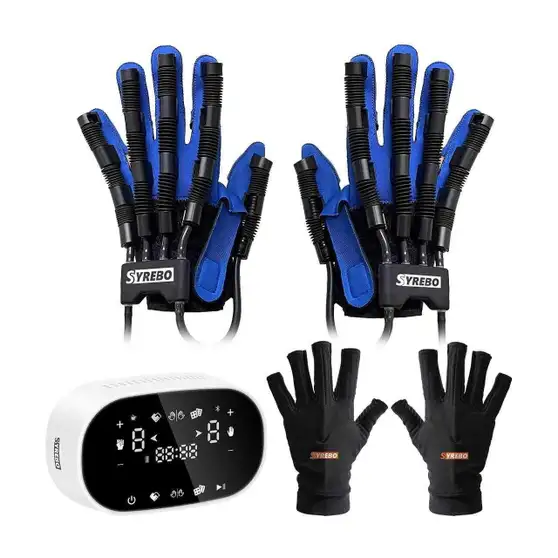
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) is a powered hand therapy device that uses a soft wearable glove to assist selected finger and hand movements.
The glove is designed to help patients practise movements that may be difficult to perform independently. Its powered assistance mechanism supports finger bending and straightening, while the available training modes allow different types of hand exercises to be incorporated into a rehabilitation plan.
Unlike conventional hand exercise tools that depend mainly on the patient’s own grip strength, a robotic rehabilitation glove can provide movement assistance according to the selected mode and device settings.
The C11 may support different exercise approaches, including:
- Passive hand movement
- Mirror-guided hand training
- Active hand movement practice
- Finger flexion and extension
- Pinch training
- Finger-splitting exercises
- Opposition training
- Stretching exercises
- Task-oriented hand practice
- Resistance-based training
The availability of individual modes should be confirmed for the exact C11 version being supplied.
How Does the Syrebo C11 Robotic Rehabilitation Glove Work?
The C11 uses a powered hand glove to assist selected finger movements. The patient’s hand is positioned inside the glove, and the controller is used to select the available training mode and settings.
Depending on the mode, the system can assist finger bending, straightening or coordinated hand movements. Some configurations also use a data glove on the unaffected hand to guide corresponding movement of the affected hand.
Soft Robotic Glove Technology
The wearable glove provides support around the fingers and hand during exercise. Its soft construction is intended to provide a flexible interface for assisted movement.
Powered Finger Movement
The powered mechanism assists selected finger flexion and extension movements. This can help patients practise opening and closing the hand when independent movement is limited.
Mirror-Guided Movement
In mirror training, movement of the unaffected hand is used to guide corresponding movement of the affected hand through the connected system.
Adjustable Movement Assistance
C11 operating documentation describes adjustable bending and stretching levels. The available adjustment range and control method should be checked against the specific device manual.
Repetitive Exercise
The device can support repeated movement practice during a defined training session. The therapist should determine the appropriate exercise duration and intensity.

Key Features of Syrebo Soft Robotic Rehabilitation Glove (C11 Model)
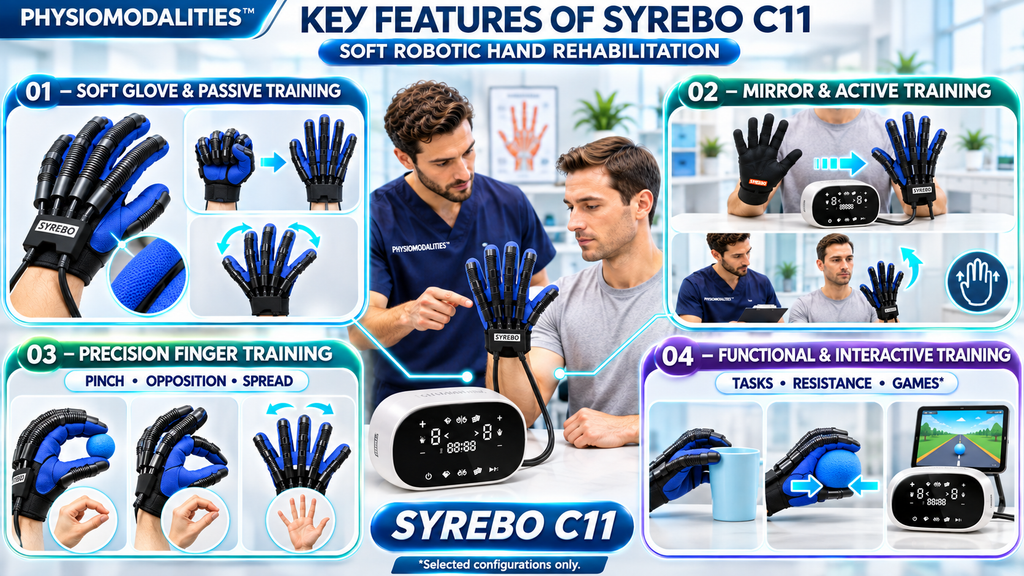
Soft Wearable Rehabilitation Glove
The C11 uses a soft robotic glove designed to fit around the hand and support selected finger movements during rehabilitation.
Passive Training
Passive training allows the powered glove to assist finger flexion and extension when the patient cannot independently complete the movement.
Mirror Training
Mirror training uses movement from the unaffected hand to guide corresponding movement of the affected hand, supporting bilateral hand practice.
Active Training
Selected C11 configurations provide active training options. These are intended for patients who can participate more actively in hand movement practice.
Pinch Training
Pinch training focuses on thumb-to-finger movement. It can include practice involving the thumb and individual fingers according to the available training program.
Finger-Splitting Training
Finger-splitting exercises focus on separating or spreading the fingers. This provides a different movement task from making a fist or closing the hand.
Opposition Training
Opposition exercises involve moving the thumb towards selected fingers. This movement is important in many everyday hand activities.
Stretching Training
Stretching mode can assist selected finger-extension or stretching exercises. The movement should remain within the patient’s prescribed and comfortable range.
Task-Oriented Training
Task-oriented exercises are designed around selected hand movements that resemble practical activities. The exact tasks available depend on the device software and configuration.
Resistance and Active-Game Options
Some C11 product listings identify resistance and active-game training. Confirm these options on the supplied unit before advertising them as included functions.
Training Modes of Syrebo C11
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) is listed with several training approaches. The exact mode selection can vary by product version, so the operating manual supplied with the unit should be treated as the final reference.
Passive Training
Passive training uses the powered glove to assist finger bending and straightening.
It may be incorporated into selected rehabilitation programs for patients who have difficulty initiating or completing hand movements independently.
Possible exercise objectives include:
- Assisted hand opening
- Assisted hand closing
- Repeated finger flexion
- Repeated finger extension
- Basic hand-mobility practice
The therapist should select the movement range and intensity according to the patient’s condition and tolerance.
Mirror Training
Mirror training uses a data glove on the unaffected hand to capture movement and guide corresponding movement of the affected hand.
This approach provides bilateral movement practice and may be incorporated into selected neurological rehabilitation programs.
It can be used for exercises involving:
- Opening the hand
- Closing the hand
- Finger movement practice
- Repeated bilateral movement
- Guided motor practice
The correct connection and operating procedure should follow the C11 user manual.
Active Training
Active training is intended for patients who can participate in generating hand movement. Depending on the configuration, the device can support active movement practice alongside powered assistance.
The therapist should determine whether the patient’s current movement ability is suitable for this mode.
Pinch Training
Pinch training focuses on thumb-to-finger movement. It may involve bringing the thumb towards the index, middle, ring or little finger in a controlled sequence.
Pinch practice can be incorporated into exercises for selected hand functions, such as holding or manipulating small objects.
Finger-Splitting Training
Finger-splitting exercises focus on separating the fingers rather than closing them together. This provides an additional movement task for hand rehabilitation.
Opposition Training
Opposition training focuses on thumb movement towards the other fingers. It can be incorporated into selected exercises that practise thumb mobility and coordination.
Stretching Training
Stretching exercises can support controlled finger extension and movement practice. The therapist should ensure that the selected movement is appropriate and does not force a stiff or painful joint.
Task-Oriented and Functional Training
Task-oriented training focuses on practising movements related to everyday hand activities. The exact tasks and program options depend on the supplied C11 software and configuration.
Applications of Syrebo Soft Robotic Rehabilitation Glove (C11 Model)
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) may be incorporated into selected rehabilitation programs involving reduced hand movement and finger-function limitations.
Stroke Rehabilitation
Stroke can affect hand movement, finger coordination and the ability to perform daily activities. The C11 may be used as one component of a professionally guided hand-rehabilitation program.
Hand Mobility Rehabilitation
The powered glove can assist selected finger flexion and extension exercises when independent movement is limited.
Neurological Rehabilitation
The C11 may be considered for selected neurological rehabilitation programs where hand movement practice is part of the treatment plan.
Finger Movement Training
The available finger-focused exercises can support practice involving bending, straightening, separation and thumb opposition.
Hand Function Practice
Pinch and task-oriented exercises can be incorporated into selected programs focused on practising hand movements used in everyday activities.
Post-Injury Rehabilitation
After appropriate assessment, the glove may be considered as part of selected hand rehabilitation programs following injury.
Postoperative Hand Rehabilitation
Use following surgery should only be considered when permitted by the treating surgeon and rehabilitation professional. The timing and movement range depend on the procedure and healing stage.
Occupational Therapy
Occupational therapists may incorporate assisted hand exercises into broader programs focused on hand coordination and functional activities.
Potential Benefits of Syrebo C11 Hand Rehabilitation Glove
The response to rehabilitation varies according to the patient’s condition, movement ability, treatment plan and consistency of practice.
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) provides features that can support structured hand exercise:
- Assists selected finger flexion and extension
- Supports repeated hand opening and closing
- Provides passive movement assistance
- Offers mirror-guided movement practice
- Includes finger-focused exercise options on supported configurations
- Supports pinch and opposition practice
- Provides stretching and task-oriented training options on listed configurations
- Uses a wearable soft-glove design
- Can be incorporated into supervised hand-rehabilitation programs
- Complements therapist-guided exercise and functional training
The device should not be described as a guaranteed treatment for paralysis, stroke or other neurological conditions. Its role should be determined through individual assessment.

Syrebo C11 for Physiotherapy and Neurorehabilitation Clinics
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) can add a dedicated hand-movement training option to a professional rehabilitation department.
Patients with reduced hand function may require repeated practice of finger bending, straightening, thumb movement and coordinated hand activities. A robotic glove can provide powered assistance for selected exercises within a broader treatment plan.
The C11 can be considered alongside:
- Hand and finger exercise equipment
- Grip-strengthening tools
- Finger rehabilitation devices
- Occupational therapy equipment
- Upper-limb rehabilitation systems
- Functional hand-training activities
- Therapeutic exercise programs
- Other appropriate neurorehabilitation interventions
The selected training mode should match the patient’s abilities and clinical objectives.
Syrebo C11 vs Conventional Hand Exercise Equipment
| Feature | Syrebo C11 Robotic Glove | Conventional Hand Exercise Equipment |
|---|---|---|
| Movement assistance | Powered assistance | Usually patient-generated |
| Passive movement | Available | Generally not powered |
| Finger flexion and extension | Assisted on supported modes | Depends on patient ability |
| Mirror training | Available on supported configuration | Requires a separate approach |
| Pinch practice | Listed on C11 configurations | Exercise or tool-dependent |
| Finger separation | Listed on C11 configurations | Exercise or tool-dependent |
| Opposition practice | Listed on C11 configurations | Exercise or tool-dependent |
| Wearable design | Soft rehabilitation glove | Varies by equipment |
| Training approach | Mode-based | Exercise-dependent |
The C11 and conventional hand exercise tools serve different purposes. They may be used together when appropriate as part of a comprehensive rehabilitation program.
How to Use the Syrebo Soft Robotic Rehabilitation Glove (C11 Model)
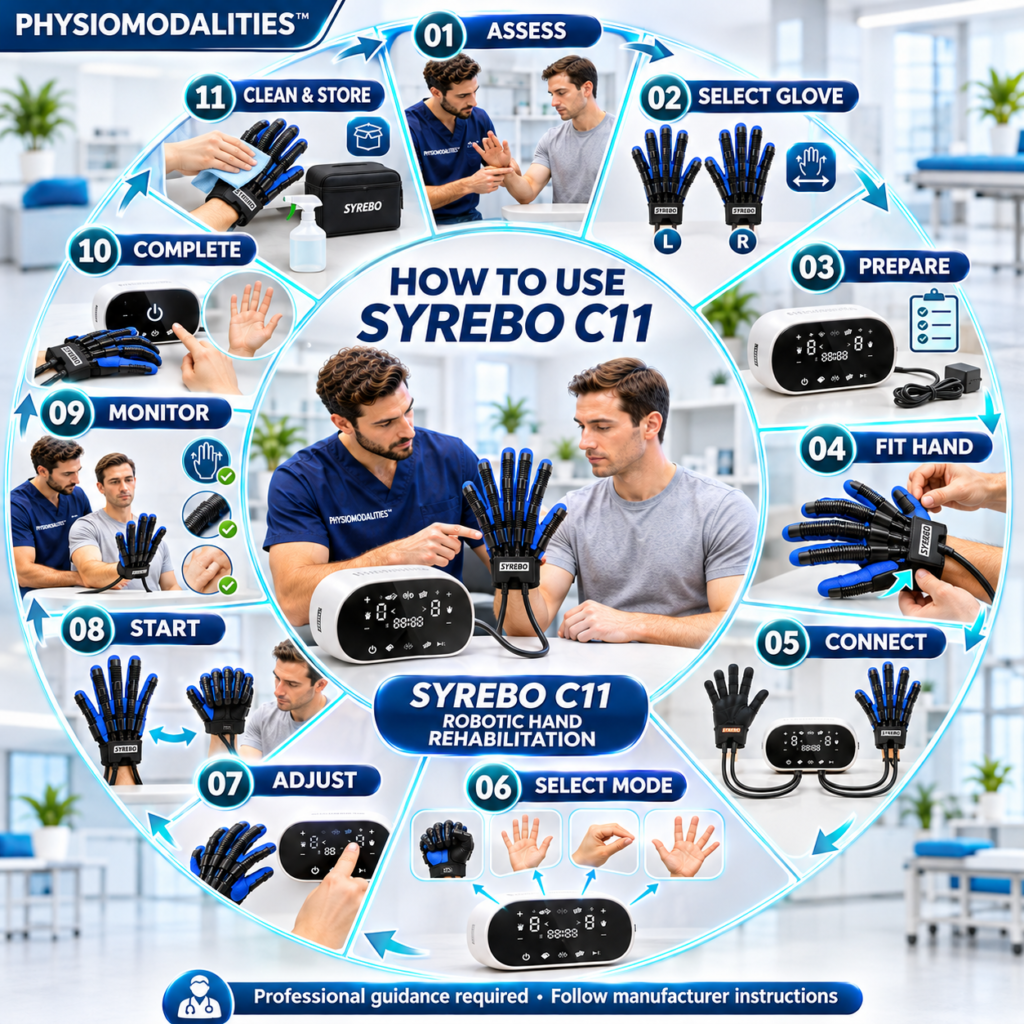
The C11 should be operated according to its supplied user manual and the patient’s rehabilitation plan. Initial fitting and mode selection should be guided by a trained professional.
Step 1: Assess the Patient
Review the patient’s hand movement, finger mobility, skin condition, sensation, comfort and relevant clinical history.
Step 2: Select the Correct Glove
Confirm the correct hand side and glove size. The glove should fit properly without excessive tightness or pressure.
Step 3: Prepare the Controller
Place the controller on a stable surface. Inspect the glove, cables, connections and power adapter before use.
Step 4: Position the Hand
Carefully place the patient’s hand inside the powered rehabilitation glove according to the manufacturer’s instructions.
Step 5: Connect the Required Glove
For mirror training, connect the data glove to the unaffected hand as described in the user manual. Other modes may require a different setup.
Step 6: Select the Training Mode
Choose the appropriate mode available on the supplied unit, such as passive, mirror, active, pinch, stretching or another supported exercise.
Step 7: Adjust the Settings
Set the available bending or stretching level according to the professional’s instructions and the patient’s tolerance.
Step 8: Begin Training
Start the selected exercise and observe the initial movement carefully. Do not force the fingers beyond the prescribed range.
Step 9: Monitor the Patient
Observe hand alignment, glove positioning, skin condition and patient comfort throughout the session.
Step 10: Complete the Session
Stop the device before removing the glove. Carefully release the patient’s hand and inspect the skin.
Step 11: Clean and Store the Equipment
Clean reusable components according to the manufacturer’s instructions and store the device safely.
Safety Precautions
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) should be used responsibly and according to the manufacturer’s instructions.
- Obtain professional guidance before starting a rehabilitation program.
- Confirm the correct glove size and hand configuration.
- Position the fingers correctly before starting the device.
- Do not force the fingers beyond their prescribed or comfortable range.
- Monitor the skin for pressure marks, redness or irritation.
- Stop use if the patient experiences pain or unusual discomfort.
- Use additional caution where hand sensation is reduced.
- Do not use a damaged glove, controller, cable or adapter.
- Follow the manufacturer’s charging and electrical instructions.
- Do not operate the device while charging if the supplied manual specifies this restriction.
- Clean reusable components according to the manufacturer’s recommendations.
- Follow the device-specific contraindications and operating instructions.
Patients with significant spasticity, fixed contractures, severe swelling, skin injuries, altered sensation or recent hand surgery should be assessed by an appropriate healthcare professional before using the device.
Technical Specifications
The following details are reported in available C11 product information. Exact specifications can vary by supplier and package.
| Specification | Details |
|---|---|
| Product Name | Syrebo Soft Robotic Rehabilitation Glove |
| Model | C11 / SY-HRC11 |
| Brand | Syrebo |
| Equipment Type | Soft Robotic Hand Rehabilitation Device |
| Primary Application | Hand and Finger Rehabilitation |
| Movement | Assisted Finger Flexion and Extension |
| Training Modes | Passive, Mirror and Active; additional modes are configuration-dependent |
| Other Listed Training | Pinch, Finger-Splitting, Opposition, Stretching and Task-Oriented |
| Hand Configuration | Left or Right Hand; package-dependent |
| Glove Size | Confirm available sizes with supplier |
| Charging Voltage | 5 V, as listed in C11 product information |
| Charging Current | 3 A, as listed in C11 product information |
| Nominal Power | 15 W, as listed by a C11 supplier |
| Controller Dimensions | Approximately 105 × 95 × 60 mm, supplier-listed |
| Glove Material | Neoprene and reinforced resin-fibre materials, supplier-listed |
| Controller Material | PC/ABS alloy and other listed components |
| Accessories | Configuration-dependent |
| Intended Use | Guided Hand and Finger Rehabilitation |
Important: Confirm the exact C11 model, training modes, glove size, hand side, materials, electrical specifications, accessories and warranty from the supplied unit’s datasheet before publishing them as fixed specifications.
Accessories and Package Contents
Available C11 supplier listings describe packages that may include:
- C11 host/controller
- Power-assisted rehabilitation glove
- Data glove
- Power adapter
- Rehabilitation ball
- Hand pillow
- User manual
Some packages are supplied for one hand, while other listings describe dual-hand configurations. Confirm the exact package supplied by PHYSIOMODALITIES™ before listing accessories as included.
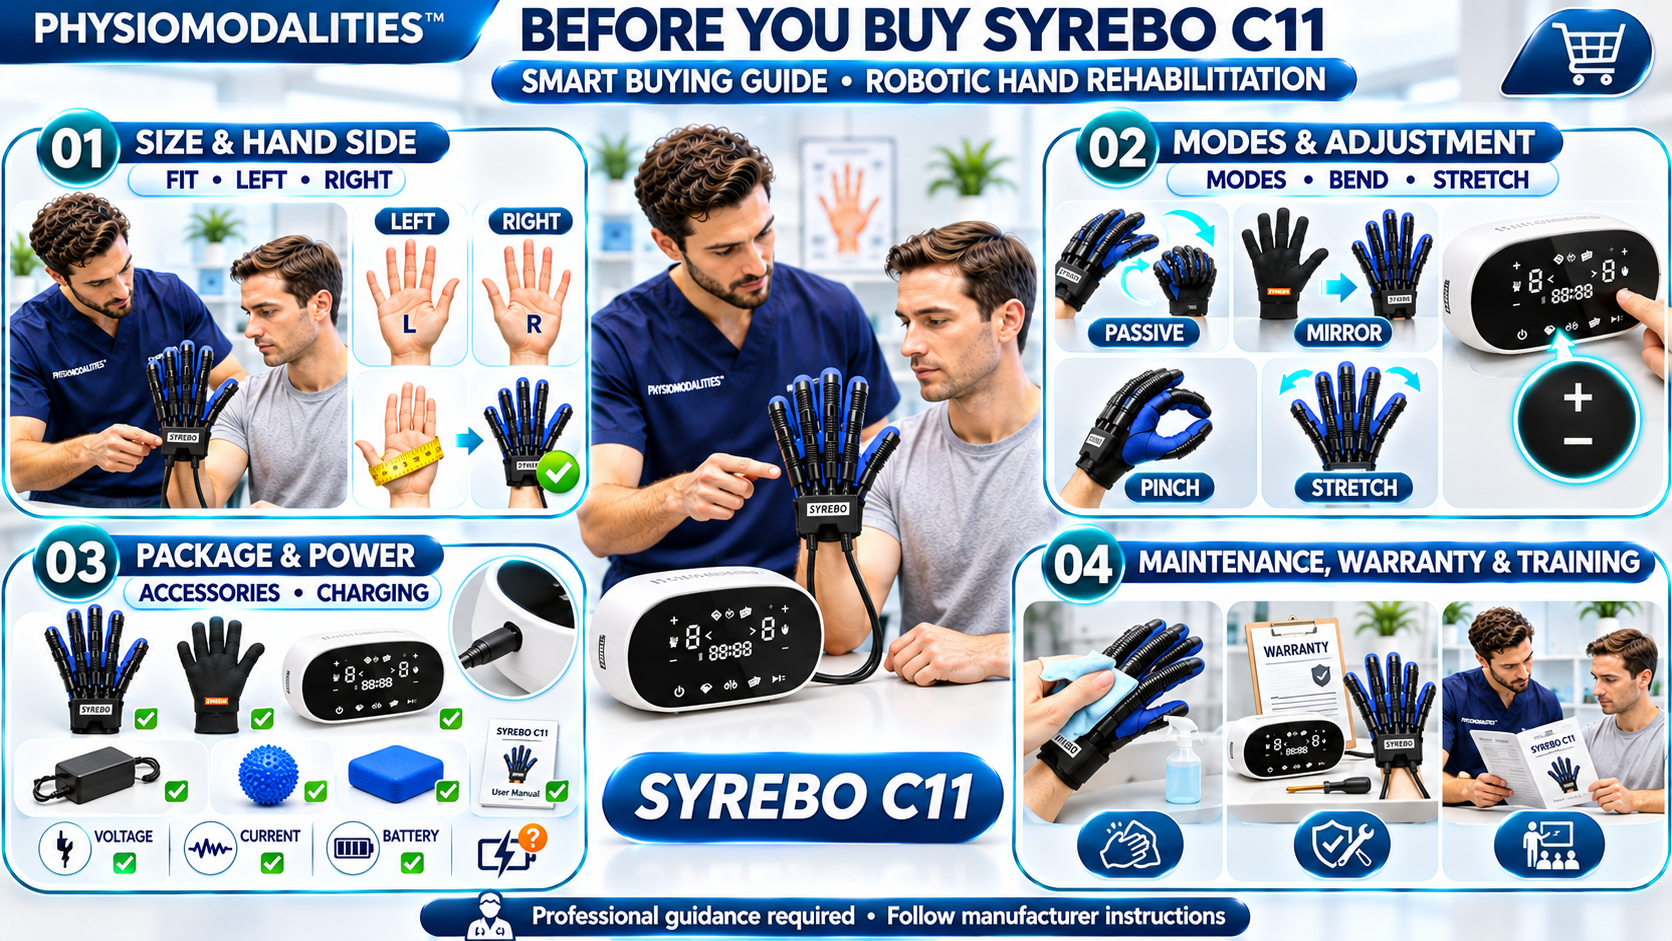
Things to Consider Before Buying
Correct Glove Size
Choose a glove size that fits the patient’s hand appropriately. Check the supplier’s size guide before ordering.
Hand Side
Confirm whether the required configuration is for the left hand, right hand or both hands.
Training Modes
Check which training modes are included in the exact C11 version. Do not assume that every advertised mode is available on every configuration.
Controller and Accessories
Confirm whether the package includes the host/controller, powered glove, data glove, adapter, rehabilitation ball, hand pillow and user manual.
Movement Adjustment
Review the available bending and stretching levels and the adjustment method described in the operating manual.
Charging Requirements
Confirm the charging voltage, current, battery details and whether the device can be operated while charging.
Cleaning and Maintenance
Check the manufacturer’s instructions for cleaning the glove and maintaining the controller and accessories.
Warranty and Technical Support
Confirm warranty coverage for the controller and wearable glove separately, if applicable. Also check service and replacement-part availability.
Professional Guidance
Ensure that the intended users and clinical staff understand the fitting procedure, training modes, operating instructions and safety precautions.
Who Should Operate the Syrebo C11?
The C11 may be used in professional rehabilitation environments under the guidance of appropriately trained healthcare professionals, including:
- Physiotherapists
- Occupational therapists
- Neurorehabilitation professionals
- Rehabilitation physicians
- Other qualified healthcare practitioners
Patients and caregivers should follow the operating and training guidance provided by the treating professional and manufacturer.
Why Choose PHYSIOMODALITIES™?
PHYSIOMODALITIES™ provides physiotherapy and rehabilitation equipment designed for professional clinical environments.
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) can complement a clinic’s hand and upper-limb rehabilitation equipment range by providing powered assistance for selected finger and hand movement exercises.
When selecting this equipment, clinics should consider the exact C11 version, glove size, hand configuration, available training modes, included accessories, warranty and after-sales support.
PHYSIOMODALITIES ENTERPRISES focuses on equipment for physiotherapy clinics, hospitals, rehabilitation centres and professional healthcare facilities.
Conclusion
The Syrebo Soft Robotic Rehabilitation Glove (C11 Model) is a powered hand rehabilitation device designed to assist selected finger and hand movements through a soft robotic glove mechanism. Its reported training options include passive movement, mirror training, active training, pinch practice, finger-splitting, opposition, stretching and task-oriented exercises, depending on the supplied configuration.
The C11 can be incorporated into selected physiotherapy, occupational therapy and neurorehabilitation programs where structured hand-movement practice is required. Before purchasing, confirm the exact training modes, glove size, hand side, controller specifications, included accessories, charging requirements and warranty.
Appropriate patient assessment, professional guidance and adherence to the manufacturer’s instructions are essential for responsible use.
Frequently Asked Questions
1. What is the Syrebo Soft Robotic Rehabilitation Glove C11?
It is a powered hand rehabilitation device designed to assist selected finger and hand movements through a soft robotic glove.
2. Which training modes are available in the C11?
C11 listings describe passive, mirror and active training, with additional options such as pinch, finger-splitting, opposition, stretching and task-oriented exercises. Availability depends on the exact configuration.
3. Can the C11 be used for stroke rehabilitation?
It may be incorporated into selected post-stroke hand-rehabilitation programs under the guidance of a qualified healthcare professional.
4. Is the C11 available for left and right hands?
C11 listings include left-hand and right-hand configurations, with some suppliers offering dual-hand packages. Confirm the required side and glove size before ordering.
5. What accessories are included with the C11?
Supplier listings describe a controller, powered rehabilitation glove, data glove, adapter, rehabilitation ball, hand pillow and user manual. The actual supplied package should be confirmed with the seller.